Patrol and alert
Build a patrol system in three milestones, a robot and a base that talk both ways, then add an alert log and status lights.
Hospitals use robots to carry medicines along set routes, and farms use them to check fences. A person starts and stops them from a base and hears from them only when something is wrong.
The assistance challenge puts the course together in a patrol system. A robot follows the line (lesson 5) and stops when blocked (lesson 3). A base station starts and stops it by radio (lesson 7), and the robot reports problems back once (lesson 9). The robot remembers its job in a mode variable (lesson 6). You will build it in three milestones, with less help each time.
As in lesson 9, both micro:bits run the same program: press A+B to make one of them the base.
- Predict: Read the code and say what it will do before you run anything. A wrong guess is fine: it shows you what to look for.
- Run: Run it and compare the result with your prediction.
- Investigate: Trace how each line of code connects to what you see.
- Modify: Change the code on purpose and check the result.
- Make: Build something new using what you have learned. Expect a few tries; that is normal.
Make your prediction first. Help opens once you've locked it in.
Predict
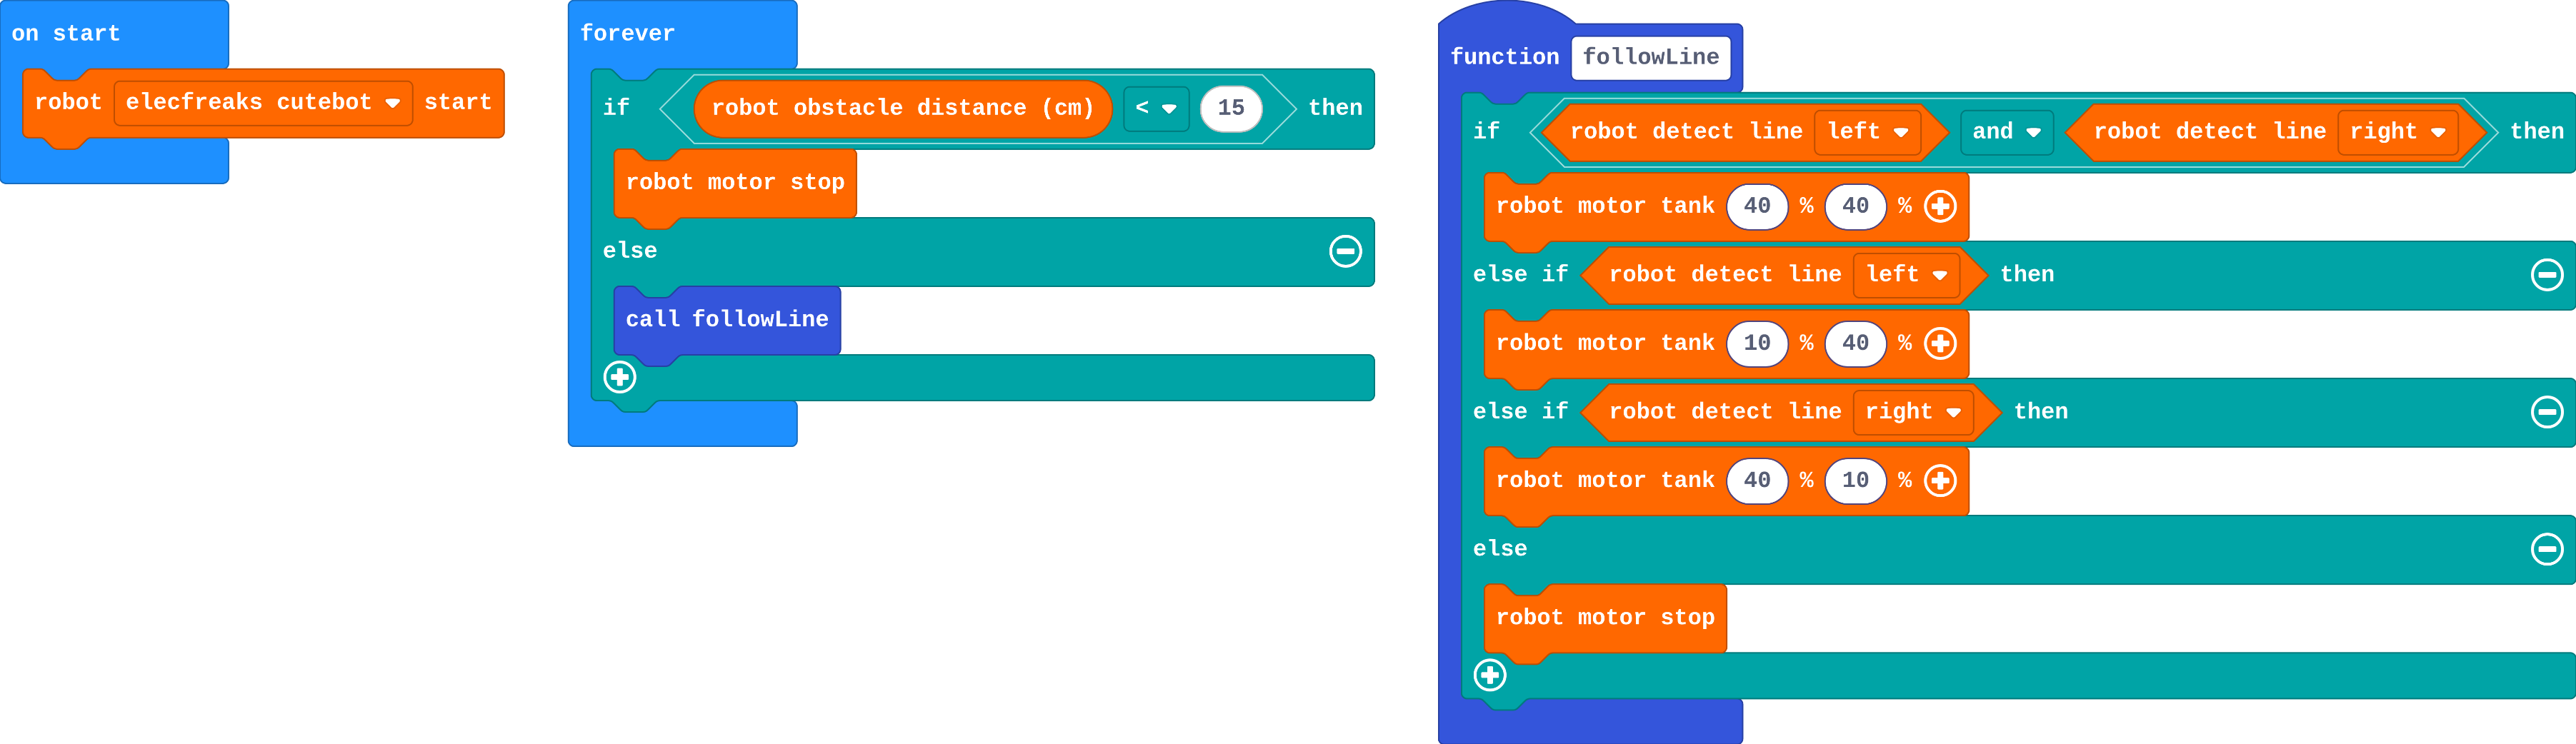
Show as code
function followLine () {
    if (robot.detectLine(RobotLineDetector.Left) && robot.detectLine(RobotLineDetector.Right)) {
        robot.motorTank(40, 40)
    } else if (robot.detectLine(RobotLineDetector.Left)) {
        robot.motorTank(10, 40)
    } else if (robot.detectLine(RobotLineDetector.Right)) {
        robot.motorTank(40, 10)
    } else {
        robot.motorStop()
    }
}
robot.elecfreaksCuteBot.start()
basic.forever(function () {
    if (robot.obstacleDistance() < 15) {
        robot.motorStop()
    } else {
        followLine()
    }
})
Run
Drag a box onto the line in front of the robot, wait, then drag it away.
Show as code
function followLine () {
    if (robot.detectLine(RobotLineDetector.Left) && robot.detectLine(RobotLineDetector.Right)) {
        robot.motorTank(40, 40)
    } else if (robot.detectLine(RobotLineDetector.Left)) {
        robot.motorTank(10, 40)
    } else if (robot.detectLine(RobotLineDetector.Right)) {
        robot.motorTank(40, 10)
    } else {
        robot.motorStop()
    }
}
robot.elecfreaksCuteBot.start()
basic.forever(function () {
    if (robot.obstacleDistance() < 15) {
        robot.motorStop()
    } else {
        followLine()
    }
})
Investigate
Show as code
function followLine () {
    if (robot.detectLine(RobotLineDetector.Left) && robot.detectLine(RobotLineDetector.Right)) {
        robot.motorTank(40, 40)
    } else if (robot.detectLine(RobotLineDetector.Left)) {
        robot.motorTank(10, 40)
    } else if (robot.detectLine(RobotLineDetector.Right)) {
        robot.motorTank(40, 10)
    } else {
        robot.motorStop()
    }
}
robot.elecfreaksCuteBot.start()
basic.forever(function () {
    if (robot.obstacleDistance() < 15) {
        robot.motorStop()
    } else {
        followLine()
    }
})
Sort each job to the robot or the base.
Jack's robot, when it hears a message:
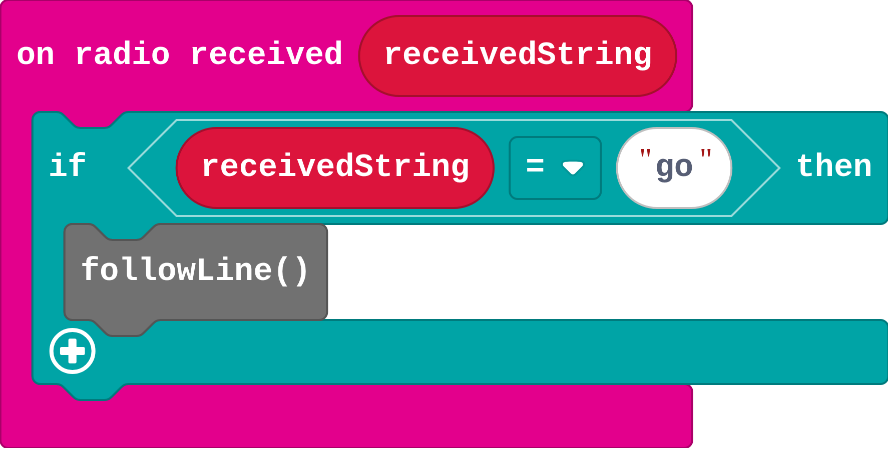
Show as code
radio.onReceivedString(function (receivedString) {
    if (receivedString == "go") {
        followLine()
    }
})
In the full patrol system, which jobs belong to the robot, and which to the base?
Milestone 1: start and stop from the base
The robot follows the line from the moment it starts. Put the base in charge:
- On the base, A sends "go" and B sends "stop".
- When a robot hears a message, it sets its mode: "patrol" for go, "stop" for stop. It starts in "stop".
- In forever, the robot follows the line only when its mode is "patrol"; otherwise it stops.
Need a hint?
On the base: A sends the word go, B sends stop (send string, in Radio).
Another hint
on radio received receivedString: if role = robot, then set mode to patrol for go, or stop for stop. Set mode to stop in on start.
Another hint
In forever, inside the robot's if: if mode = patrol, follow the line; else, robot motor stop.
The base's A sends 'go' and B sends 'stop'; the robot patrols only while its mode is patrol.
This ticks by itself when your blocks do what is asked.
Milestone 2: report back
Make the robot report problems:
- While patrolling, if something is in the way, the robot stops and sends "blocked", once.
- When the way is clear again, it sends "clear", once, and carries on.
- The base shows an X and beeps for blocked, and a tick for clear.
Need a hint?
While patrolling: if the distance is less than 15, stop, and send 'blocked' if not alerted (then set alerted to true). Else send 'clear' if alerted, set alerted to false, and follow the line.
Another hint
On the base, in on radio received: else if role = base, show an X and beep for 'blocked', and a tick for 'clear'.
The patrolling robot stops when blocked and tells the base once ('blocked', then 'clear'); the base shows an X and beeps, then a tick.
This ticks by itself when your blocks do what is asked.
Milestone 3: a log and status lights
Finish the system:
- The base keeps a log: it counts the alerts and shows the count when its logo is touched.
- The robot shows its status in its lights: green while patrolling, red when blocked, off when stopped.
Then make it yours: a hospital delivery robot, a fence checker or a warehouse patrol. Change the messages and pictures to suit.
Need a hint?
A variable alerts on the base: change by 1 for each 'blocked'. The logo shows it.
Another hint
robot set color in three places: green while patrolling, red when blocked, off when stopped.
The base counts the alerts and shows the count on its logo; the robot's lights show green (patrolling), red (blocked) or off (stopped).
This ticks by itself when your blocks do what is asked.
On a real robot
Set up a tape loop and put a bare micro:bit with a person as the base (press A+B on it). Things to notice:
- Every patrol team needs its own radio group.
- A real robot stops at people's feet too: that is a feature, not a bug.
- If the robot goes out of radio range its messages are lost. What should a real patrol robot do then? (Real ones store them and send them later.)
For teachers
The assistance challenge. Students build a patrol system in three milestones (the base starts and stops the robot by radio, the robot reports blockages once, then an alert log and status lights), combining line following, distance, modes, roles and two-way radio. About 60 minutes.
Open the teacher guide: answers, solutions, slides and a worksheet.
Students will be able to
- I can control a robot's mode from a base station by radio.
- I can make a robot report a problem once, and report when it is fixed.
- I can give a system a log and a visible status.
Before class
This is the assistance strand's challenge, using lessons 3 and 5 (distance and line), 6 (mode), 7 (radio commands) and 9 (roles and alert once). The key design rule: radio handlers only change the mode; forever drives the motors. A move made in a handler would be undone straight away by forever (or, like Jack's patrol, would only run once).
Both micro:bits run the same program; A+B makes one the base. The base's A sends "go", B sends "stop". The robot sends "blocked" (once, using alerted) and "clear". The milestones fade the help: Milestone 1 gives three numbered steps, Milestone 2 an outline, Milestone 3 goals only. Each starter is the previous milestone's solution. Showcase and Patrol and alert together mark the course Challenge complete.
The robots start near the line in the simulator; if one does not pick it up, drag it on. The logo needs a micro:bit V2 (shake works on V1).
Running the lesson
- Predict and Run: a recap of lessons 3 and 5. Make sure everyone can block and unblock the robot.
- Investigate: the sort shows the system's two halves. Jack's patrol is the run-once slip in a new place: a handler runs once per message.
- Milestone 1: three steps on the board: send a word, set the mode, act on the mode.
- Milestone 2: the alerted pattern from lesson 9, now with 'clear' too. Test by blocking and unblocking the patrolling robot.
- Milestone 3: a log and status lights. Let groups choose a setting (hospital, farm, warehouse) and rename messages.
- Real robot (optional): one bare micro:bit as the base per team, each team its own radio group.
The hard part (on purpose)
Each side has its own job, and radio handlers only set the mode. Ask which part of the program drives the motors.
When students get stuck
- The robot never moves after 'go'. Ask: What is the robot's role? Does forever check the mode? Fix: Only the robot's micro:bit sets mode; forever follows the line when mode = patrol. Press A on the base, not the robot.
- The base beeps again and again. Ask: Is 'blocked' sent only if not alerted? Fix: Send it inside if not alerted, then set alerted to true.
- The base and robot both react to the same message. Ask: Does on radio received check the role? Fix: Robot jobs inside if role = robot; base jobs inside else if role = base.
Stretch and support
Stretch: Add a 'home' command: the base's logo sends 'home' and the robot turns round (a 'turn' mode that spins for 1.2 seconds, then goes back to patrol).
Support: Pair students for Milestone 2: one builds the robot side, one the base side, then they agree the words.
Where it leads
Real-world links: hospital delivery robots, farm fence checkers, warehouse robots, pipeline inspection. Discussion: what should the robot do when it cannot reach the base?
What each step is for
- Investigate: In a two-way system each side has its own jobs. Radio handlers only change what the robot remembers (its mode); forever does the driving.
- Milestone 1: start and stop from the base: A message changes the mode; forever does the job for the mode.
- Milestone 2: report back: Two-way radio needs a few agreed words, each sent once, with each side knowing what they mean.
- Milestone 3: a log and status lights: A finished system tells people what is happening: a log of what went wrong, and a status you can see from across the room.
- Control a robot's mode from a base station by radio.
- Make a robot report a problem once, and report when it is fixed.
- Give a system a log and a visible status.