Report back
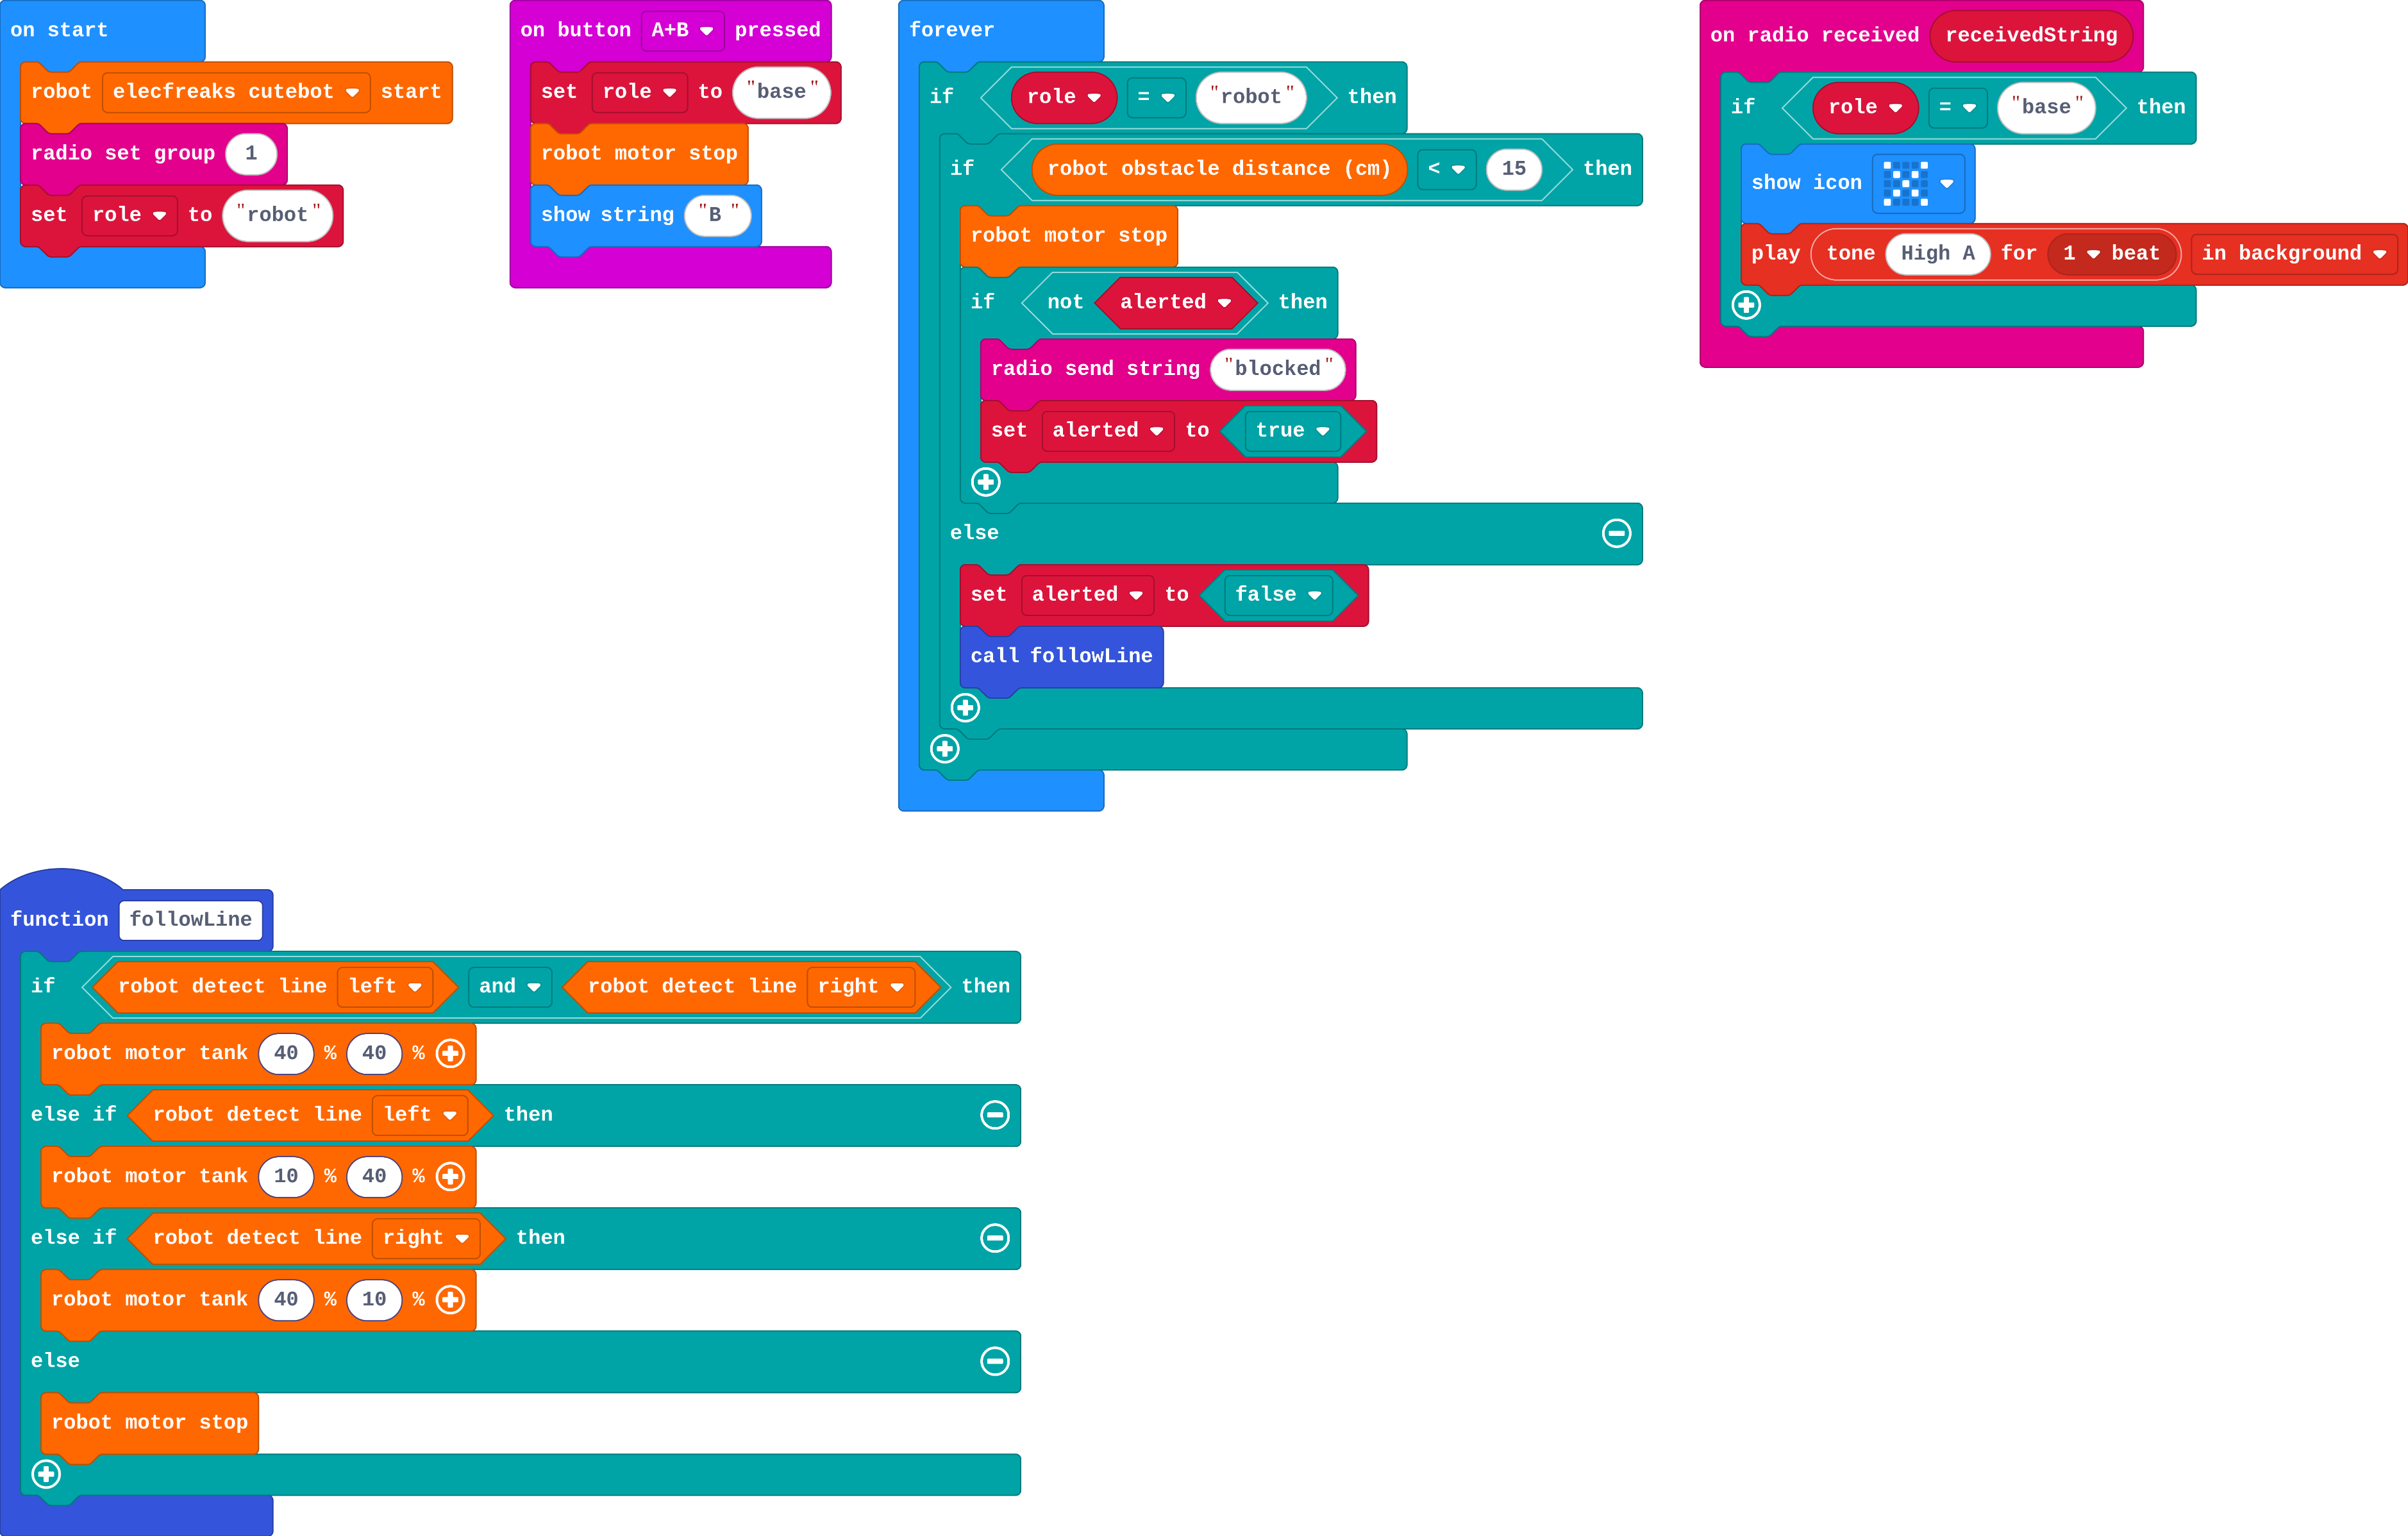
A patrol robot sends an alert to a base station when its way is blocked, once, using a variable to remember it has already told.
Inspection robots patrol pipelines, warehouses and bush tracks on their own. They only call a person when they find something: a leak, a spill, a fallen tree.
So far a person told the robot what to do. Now the robot does its job on its own and reports back. It follows the line (lesson 5); when something blocks it, it stops and sends "blocked" by radio to a base station.
Both micro:bits run the same program, so each one has a role. Every micro:bit starts as a robot. Pressing A+B makes it the base: it stops driving and listens for alerts.
A true/false variable, alerted, remembers whether the robot has already told the base. if not alerted asks the opposite question: not (in Logic) turns true into false and false into true, so it runs only while alerted is still false.
- Predict: Read the code and say what it will do before you run anything. A wrong guess is fine: it shows you what to look for.
- Run: Run it and compare the result with your prediction.
- Investigate: Trace how each line of code connects to what you see.
- Modify: Change the code on purpose and check the result.
- Make: Build something new using what you have learned. Expect a few tries; that is normal.
Make your prediction first. Help opens once you've locked it in.
Predict
Show as code
function followLine () {
    if (robot.detectLine(RobotLineDetector.Left) && robot.detectLine(RobotLineDetector.Right)) {
        robot.motorTank(40, 40)
    } else if (robot.detectLine(RobotLineDetector.Left)) {
        robot.motorTank(10, 40)
    } else if (robot.detectLine(RobotLineDetector.Right)) {
        robot.motorTank(40, 10)
    } else {
        robot.motorStop()
    }
}
input.onButtonPressed(Button.AB, function () {
    role = "base"
    robot.motorStop()
    basic.showString("B")
})
radio.onReceivedString(function (receivedString) {
    if (role == "base") {
        basic.showIcon(IconNames.No)
        music.play(music.tonePlayable(880, music.beat(BeatFraction.Whole)), music.PlaybackMode.InBackground)
    }
})
let alerted = false
let role = ""
robot.elecfreaksCuteBot.start()
radio.setGroup(1)
role = "robot"
basic.forever(function () {
    if (role == "robot") {
        if (robot.obstacleDistance() < 15) {
            robot.motorStop()
            if (!(alerted)) {
                radio.sendString("blocked")
                alerted = true
            }
        } else {
            alerted = false
            followLine()
        }
    }
})
Run
Press A+B on the second micro:bit: it shows B and its robot stops. Drag a box onto the line in front of the first robot. Then drag the box away and let it patrol on.
Show as code
function followLine () {
    if (robot.detectLine(RobotLineDetector.Left) && robot.detectLine(RobotLineDetector.Right)) {
        robot.motorTank(40, 40)
    } else if (robot.detectLine(RobotLineDetector.Left)) {
        robot.motorTank(10, 40)
    } else if (robot.detectLine(RobotLineDetector.Right)) {
        robot.motorTank(40, 10)
    } else {
        robot.motorStop()
    }
}
input.onButtonPressed(Button.AB, function () {
    role = "base"
    robot.motorStop()
    basic.showString("B")
})
radio.onReceivedString(function (receivedString) {
    if (role == "base") {
        basic.showIcon(IconNames.No)
        music.play(music.tonePlayable(880, music.beat(BeatFraction.Whole)), music.PlaybackMode.InBackground)
    }
})
let alerted = false
let role = ""
robot.elecfreaksCuteBot.start()
radio.setGroup(1)
role = "robot"
basic.forever(function () {
    if (role == "robot") {
        if (robot.obstacleDistance() < 15) {
            robot.motorStop()
            if (!(alerted)) {
                radio.sendString("blocked")
                alerted = true
            }
        } else {
            alerted = false
            followLine()
        }
    }
})
Investigate
Show as code
function followLine () {
    if (robot.detectLine(RobotLineDetector.Left) && robot.detectLine(RobotLineDetector.Right)) {
        robot.motorTank(40, 40)
    } else if (robot.detectLine(RobotLineDetector.Left)) {
        robot.motorTank(10, 40)
    } else if (robot.detectLine(RobotLineDetector.Right)) {
        robot.motorTank(40, 10)
    } else {
        robot.motorStop()
    }
}
input.onButtonPressed(Button.AB, function () {
    role = "base"
    robot.motorStop()
    basic.showString("B")
})
radio.onReceivedString(function (receivedString) {
    if (role == "base") {
        basic.showIcon(IconNames.No)
        music.play(music.tonePlayable(880, music.beat(BeatFraction.Whole)), music.PlaybackMode.InBackground)
    }
})
let alerted = false
let role = ""
robot.elecfreaksCuteBot.start()
radio.setGroup(1)
role = "robot"
basic.forever(function () {
    if (role == "robot") {
        if (robot.obstacleDistance() < 15) {
            robot.motorStop()
            if (!(alerted)) {
                radio.sendString("blocked")
                alerted = true
            }
        } else {
            alerted = false
            followLine()
        }
    }
})
Look at where alerted is set to true, and where it goes back to false.
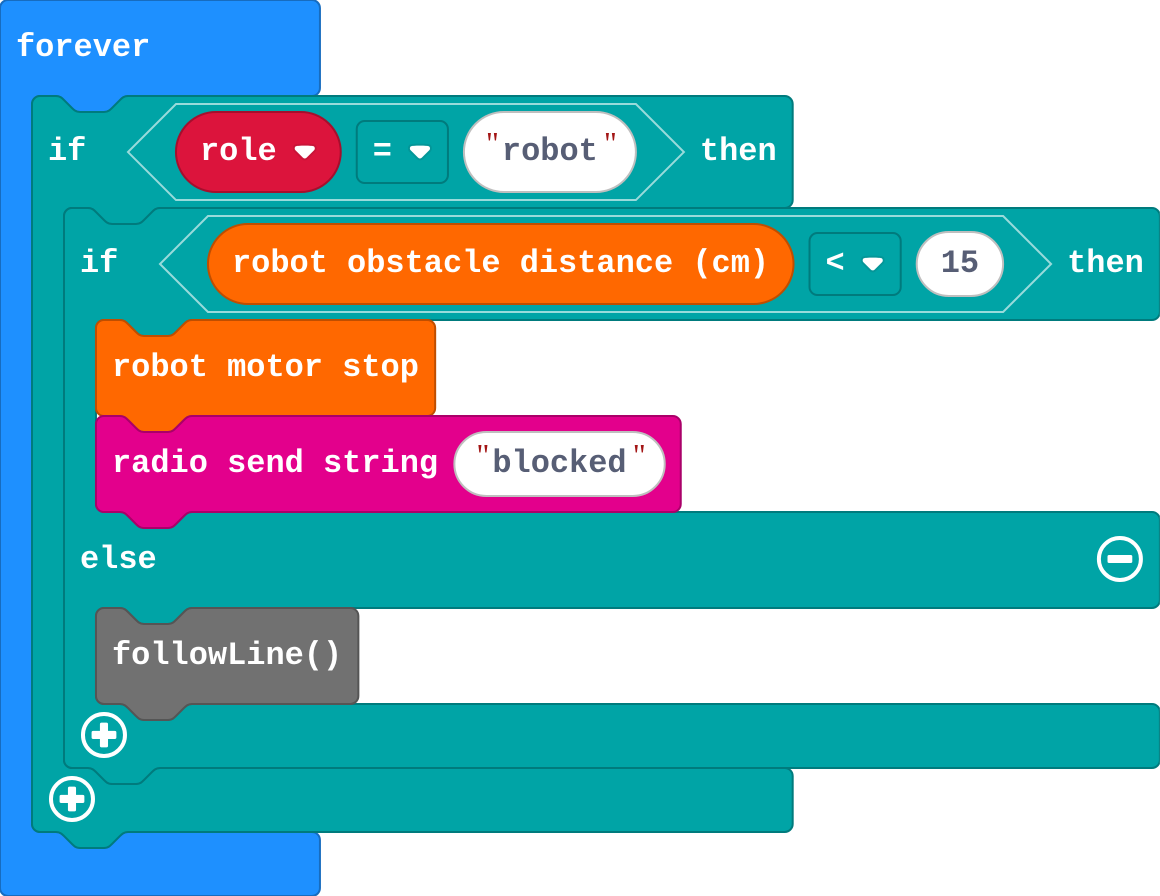
Noah's robot (the rest of his program is the same):
Show as code
basic.forever(function () {
    if (role == "robot") {
        if (robot.obstacleDistance() < 15) {
            robot.motorStop()
            radio.sendString("blocked")
        } else {
            followLine()
        }
    }
})
Modify
A person at the base wants to know when the problem is fixed. When the way is clear again, the robot sends "clear" (once), and the base shows a tick.
Need a hint?
In the robot's else, before alerted is set to false: if alerted, send 'clear'.
Another hint
On the base: if receivedString = 'clear', show a tick (icon Yes); else show the X and beep.
Make the base count the alerts and show how many there have been, like a log of a shift's problems.
Need a hint?
Make a variable alerts. On the base, when the message is not 'clear': change alerts by 1.
Another hint
Then show number alerts instead of the X.
When the way is clear again, the robot sends 'clear' once, and the base shows a tick.
This ticks by itself when your blocks do what is asked.
The base counts the alerts and shows how many there have been.
This ticks by itself when your blocks do what is asked.
Make
Make a snake spotter for a bush track. The robot patrols the line; when something is in the way it:
- stops, shows red lights and sends "snake" to the base
- waits two seconds, then turns round and patrols back
The base shows the snake picture and sounds an alarm.
Need a hint?
In the robot's forever: if the distance is less than 15, stop, red lights, send 'snake', pause 2000, then turn round (motor tank 50 −50 for 1200 ms). Else follow the line.
Another hint
On the base: if the message is 'snake', show icon snake and play an alarm. Once it has turned round, the box is behind it, so it sends once.
A snake spotter: the robot patrols, and when something is in the way it stops, alerts 'snake', waits, then turns back; the base shows a snake and sounds an alarm.
This ticks by itself when your blocks do what is asked.
On a real robot
With real micro:bits, one stays with a person as the base (press A+B on it) and the other goes in the robot. Things to notice:
- Use your own radio group, as in lesson 7.
- Radio has a range: a patrol robot that goes too far, or behind a wall, cannot be heard. Real inspection robots store their alerts and send them when they are back in range.
- A real sensor sees walls and people too: a patrol robot needs a clear track.
For teachers
Students make a patrol robot that follows the line and sends a radio alert to a base station when it is blocked, using a true/false variable so it alerts once, then build a snake spotter. About 50 minutes.
Open the teacher guide: answers, solutions, slides and a worksheet.
Students will be able to
- I can make a robot send a radio message when its sensor detects something.
- I can use a true/false variable so a message is sent once, not every time round.
- I can give one program two roles (robot and base) with a variable.
Before class
This is the assistance strand: lesson 5's line following plus lesson 7's radio, in the other direction. The robot works on its own and reports back. Two new ideas:
- Send once. forever runs many times a second, so an alert inside it would be sent again every time round while the box is there (Noah's patrol). A true/false variable, alerted, remembers that the robot has already told; it goes back to false when the way is clear. Students met true/false variables in the Foundations challenge (no cheating in the reaction timer).
- Roles. Because the simulator runs the same program on both micro:bits, a role variable decides what each one does: every micro:bit starts as a robot; A+B makes it the base, which stops and listens.
Messages are words (send string, on radio received receivedString). On real hardware the base can be a bare micro:bit (untested whether the robot start block errors without a robot; if so, give the base a copy without it).
Running the lesson
- Predict: most expect one beep; some expect continuous beeping. Both are worth hearing before Noah's patrol.
- Run: press A+B on the second micro:bit first. Then block the first robot with a box on the line.
- Investigate: trace alerted on the board: false → true (send) → stays true (no send) → false when clear.
- Modify: 'clear' is sent once for the same reason: only when alerted was true.
- Make: the snake spotter turns round, so the box ends up behind it: it sends once without needing alerted. Ask why.
- Real robot (optional): range and walls matter; discuss what a real inspection robot should do out of range.
The hard part (on purpose)
An alert in forever is sent every time round unless a flag remembers it. Ask what stops the robot sending again.
When students get stuck
- The base never reacts. Ask: Did you press A+B on the base? Is the box on the other robot's line? Fix: Make one micro:bit the base first, then block the other robot.
- The base beeps again and again. Ask: What stops the robot sending every time round? Fix: Use alerted: send only if not alerted, then set alerted to true.
- 'clear' is sent all the time. Ask: Is the send inside if alerted? Fix: Send clear only when alerted is true, then set it to false.
Stretch and support
Stretch: Two-way: the base sends 'go' with A, and a robot that has stopped waits for 'go' before it carries on (a mode variable from lesson 6).
Support: Give the base side complete; students add the robot's alert with the alerted variable.
Where it leads
Next: the challenge unit. Showcase (performance) and Patrol and alert (assistance) put the course together. Real-world links: pipeline and warehouse inspection robots, wildlife cameras that send an alert, smoke alarms that report to a phone.
What each step is for
- Investigate: forever keeps checking, so an alert in forever would be sent again every time round. A true/false variable remembers that the robot has already told, so it tells once.
- Modify: The robot and the base agree on a few message words; each new word needs a sender and a meaning.
- Make a robot send a radio message when its sensor detects something.
- Use a true/false variable so a message is sent once, not every time round.
- Give one program two roles (robot and base) with a variable.