Avoid and explore
Students use if … else inside forever so the robot turns away from close objects and keeps exploring, then add a random turn to make a robot vacuum.
Classroom resources
Load these into Waypoints Prepare: choose Load URL and paste the copied address, or download the file and import it. In Prepare, the worksheet's Teacher edition shows the answers; the student copy hides them.
Students will be able to
- I can use if … else in forever so the robot chooses between two moves.
- I can put a short routine (back up, then turn) in a branch.
- I can use a random choice so the robot does not always turn the same way.
Timing
Predict and Run 8 min · Investigate 8 min · Modify 12 min · Make 12 min · Real robot 5 min (optional)
Before class
This lesson builds on Stop before you crash: the same distance question, but the answer is now a choice of two moves. if the distance is less than 15, turn away; else, drive forward. Inside forever, the robot checks and chooses again every time round, so it explores without a plan, which is how simple robot vacuums cover a floor.
In this simulator the distance sensor only sees boxes and other robots, not the arena's walls, so robots may bump a wall and slide along it. Say so up front; it is a good discussion of how a simulation differs from the real thing. A real sensor sees walls, but weakly at an angle.
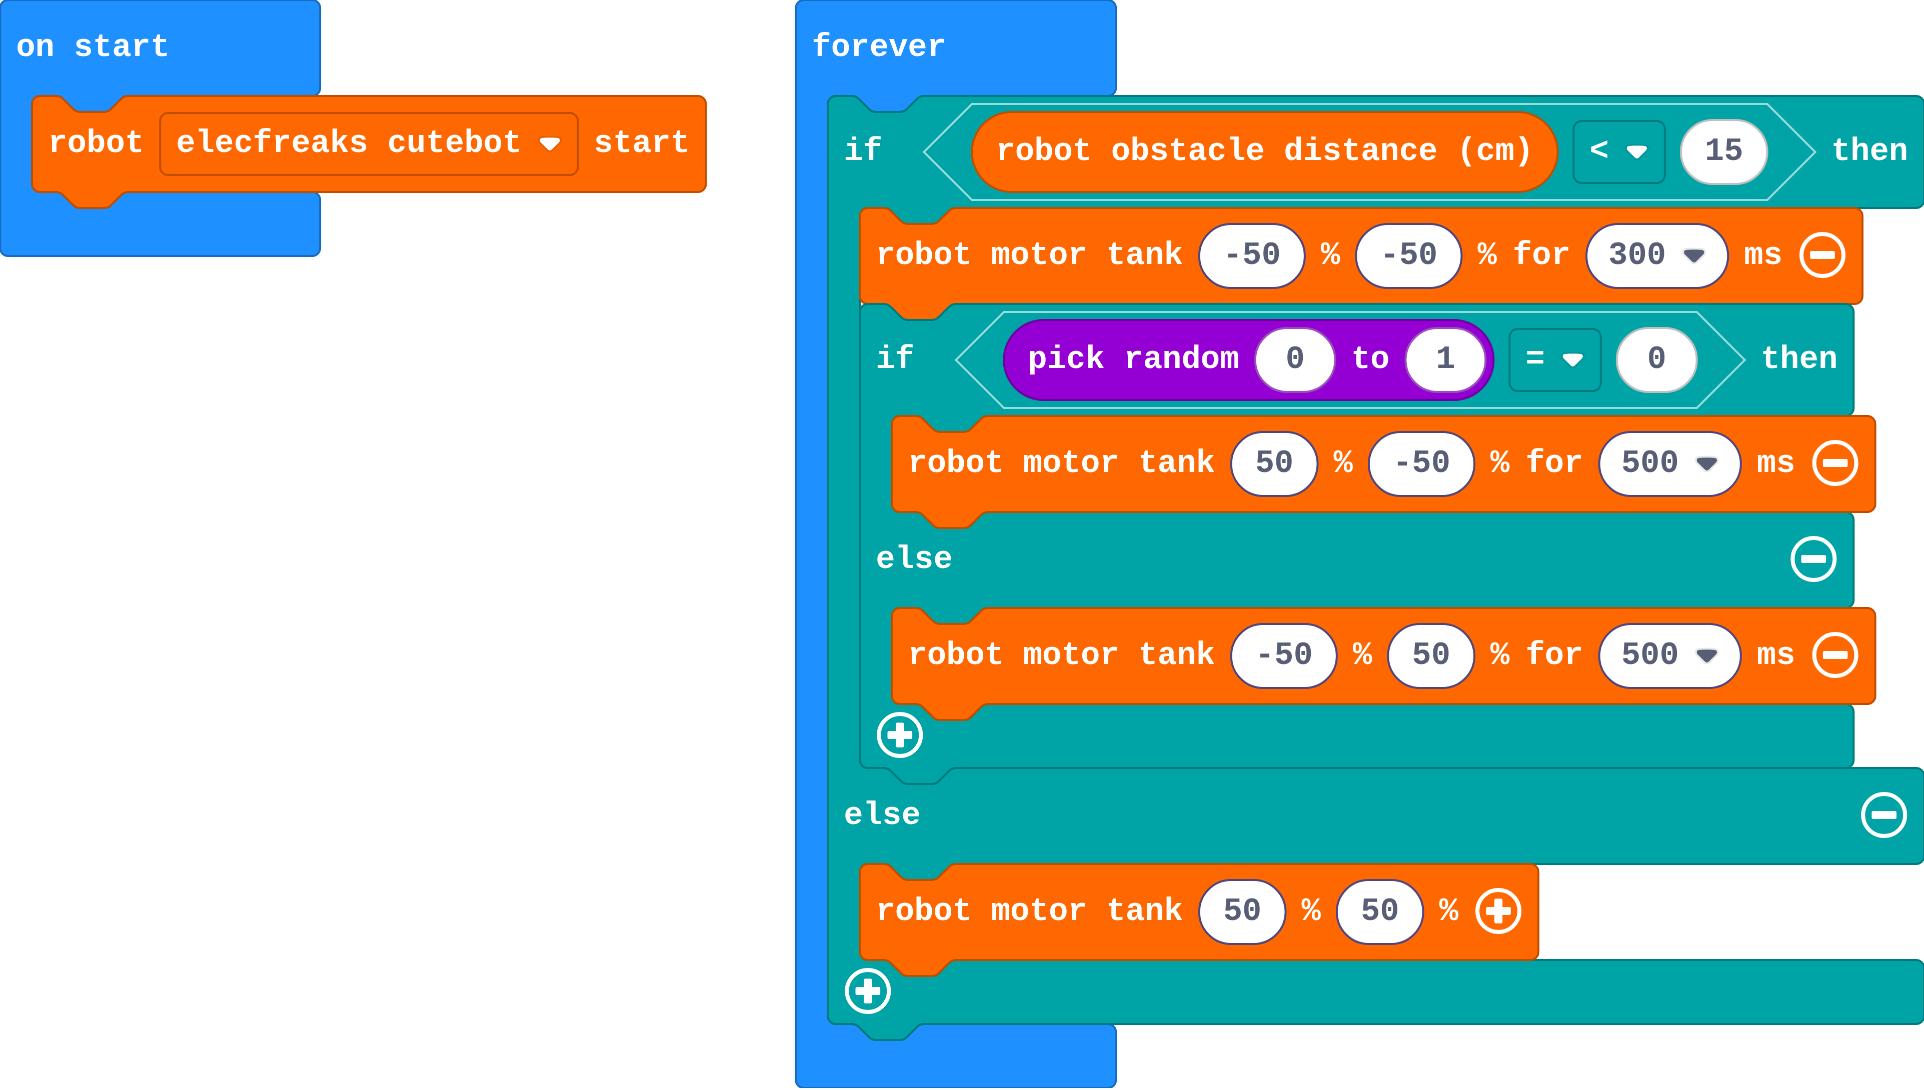
pick random 0 to 1 (in Math, randint in code) gives 0 or 1. A second if … else inside the first picks the turn direction. Schools with MOVE Motor robots can use Kitronik's measure distance with the same logic on the real robot.
Running the lesson
- Predict: most predict it turns away. Ask what makes it drive forward again afterwards.
- Run: drag boxes into its path. Mention the walls before anyone asks.
- Investigate: Zara's robot is the < and > mix-up from micro:bit Foundations; it is very visible here.
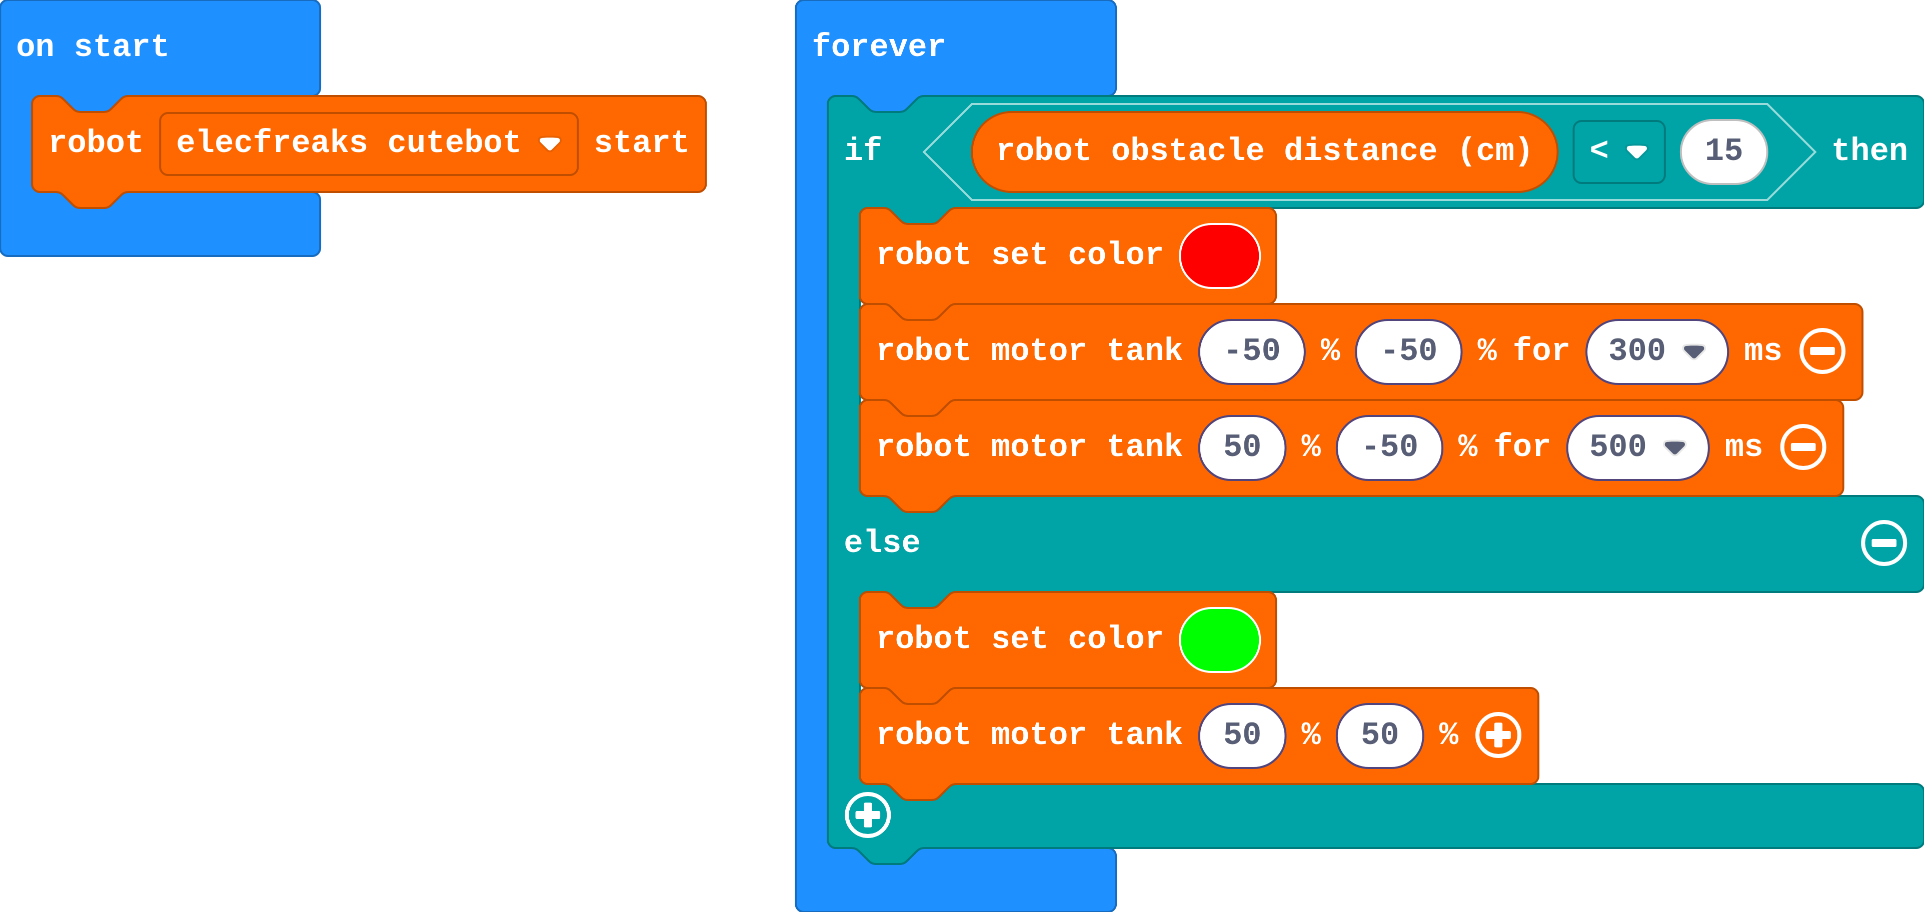
- Modify: −50 −50 backs up. Colours: robot set color, click the swatch.
- Make: an if … else inside an if is new for some. Draw the decision as a tree on the board: close? then coin toss: left or right.
- Real robot (optional): book walls work well. Soft objects are hard for ultrasonic sensors.
The hard part (on purpose)
if … else chooses a move every time round, with no plan. Ask them to read the question aloud and say when it is true.
When students get stuck
| What you will see | A question to ask | The fix |
|---|---|---|
| The robot spins in the open and hits boxes. | Read the question aloud: when is it true? | Use < (less than): turn when the distance is small. |
| The robot gets stuck turning back and forth. | Does it turn far enough to see past the box? | Make the turn longer (700 ms), or back up first. |
| It always turns the same way. | Where does the random choice go? | Inside the first if: if pick random 0 to 1 = 0, turn right, else turn left. |
Answers to the checks
- Predict: The robot drives towards a box. What happens?
It turns away and keeps exploring. When the box is closer than 15 cm, it turns for half a second; once the way is clear, else drives it forward again. - Back to forward: After turning away, how does the robot know to drive forward again?
forever runs the if again: the box is no longer close, so else drives forward
forever checks again straight after the turn. The way is clear now, so the question is false and else runs: drive forward. - Zara's robot: Zara's robot spins on the spot in open space, and drives straight into boxes. Which part is wrong?
The > should be <: her robot turns when things are far away and drives when they are close
'distance > 15' is true when nothing is near, so Zara's robot turns in open space. When a box is close, the question is false and else drives straight at it.
Solutions
One possible solution for each task. Other correct programs are fine.
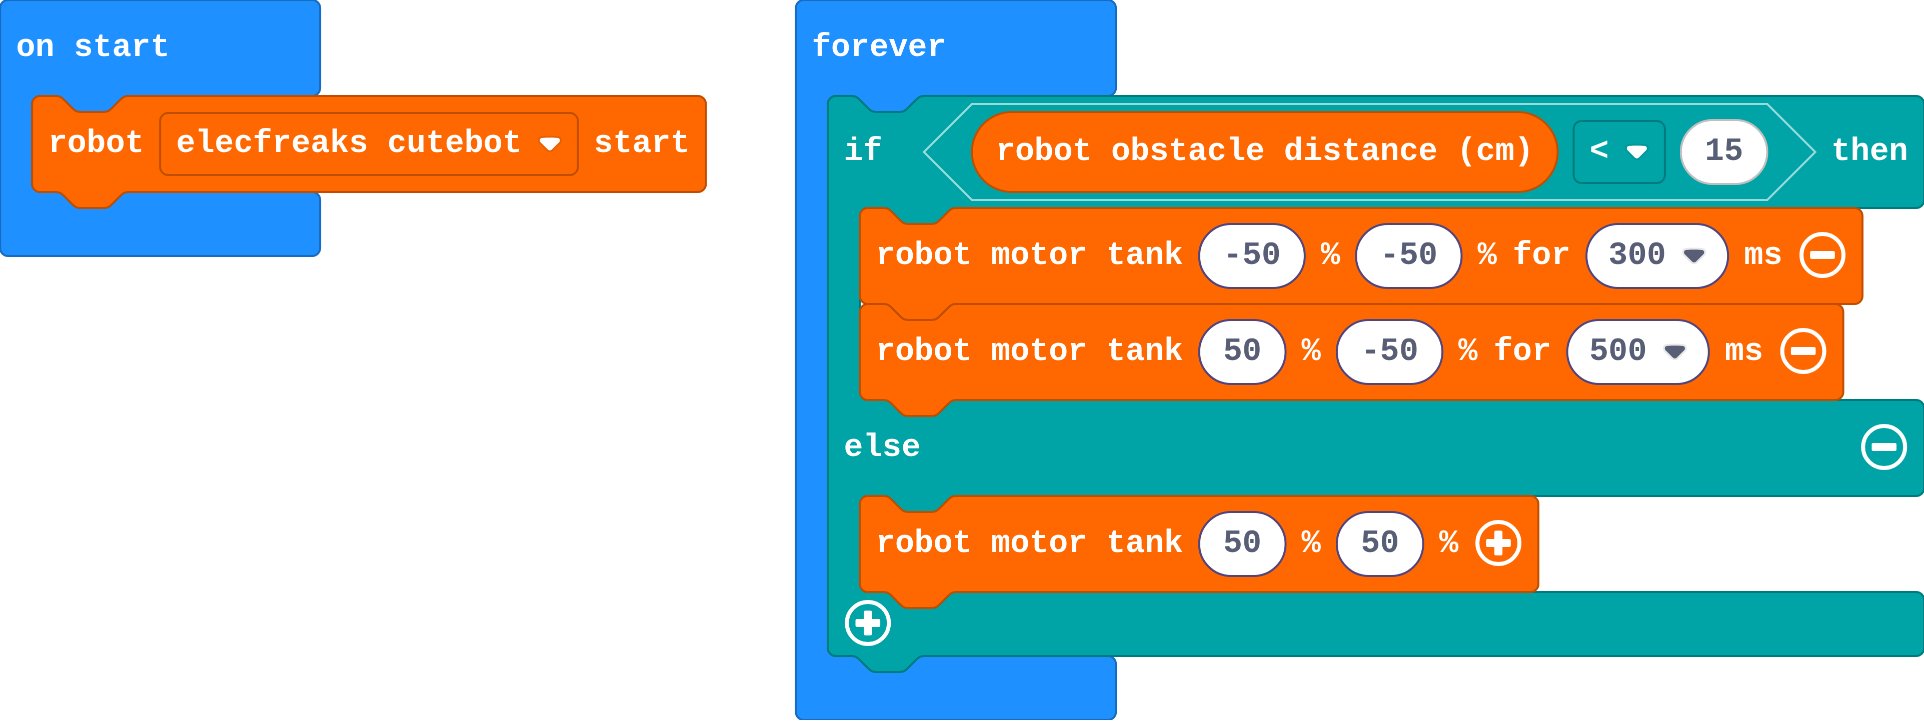
Modify › Back up first
Show as code
robot.elecfreaksCuteBot.start()
basic.forever(function () {
    if (robot.obstacleDistance() < 15) {
        robot.motorTank(-50, -50, 300)
        robot.motorTank(50, -50, 500)
    } else {
        robot.motorTank(50, 50)
    }
})
Modify › Indicator lights
Show as code
robot.elecfreaksCuteBot.start()
basic.forever(function () {
    if (robot.obstacleDistance() < 15) {
        robot.setColor(0xff0000)
        robot.motorTank(-50, -50, 300)
        robot.motorTank(50, -50, 500)
    } else {
        robot.setColor(0x00ff00)
        robot.motorTank(50, 50)
    }
})
Make
Show as code
robot.elecfreaksCuteBot.start()
basic.forever(function () {
    if (robot.obstacleDistance() < 15) {
        robot.motorTank(-50, -50, 300)
        if (randint(0, 1) == 0) {
            robot.motorTank(50, -50, 500)
        } else {
            robot.motorTank(-50, 50, 500)
        }
    } else {
        robot.motorTank(50, 50)
    }
})
Stretch and support
Stretch: Count how many times the robot has turned away (a variable, change by 1) and show it on the micro:bit.
Support: Give the random if … else with its question already set; students put a turn in each branch.
Exit ticket
How does if … else inside forever let a robot explore a room without a plan?
Every time round, it checks the distance and chooses: turn away if something is close, else drive forward. Many small choices add up to exploring.
What each step is for
- Investigate: Inside forever, if … else chooses one of two moves every time round. The robot never plans: it keeps checking and choosing.
- Modify: Each branch can hold a short routine, not just one move.
Where it leads
Next: follow a line instead of exploring at random. Real-world link: early robot vacuums worked like this; newer ones map the room.